AQUARM
AQUARM is a compact, modular manipulator system designed for stable underwater operation.
Its high torque density design delivers stable output and precise control, and it integrates flexibly with underwater robotic platforms and operating environments.
For teleoperation, it pairs with a master arm that intuitively translates operator motion, enabling natural and precise remote manipulation.
Hardware Overview
| Parameter | Specification |
|---|---|
| Degrees of Freedom | 6 + 1 (6-axis arm + interchangeable gripper) |
| Max Reach | 447.5 mm |
| Working Range | Ø930 mm |
| Payload | 3 kgf |
| Weight (arm) |
|
| Joint Range | Multi-turn (up to 6862 rad, all joints ) |
| Joint Speed | 150 °/s (rated) |
| Joint Torque |
|
| Backlash | ≤ 15 arcsec |
| Repeatability | ≤ 0.01 mm |
| Supply Voltage | 20 – 48 V |
| Communication | Ethernet 100 Mbps (UDP) / CAN FD (internal) |
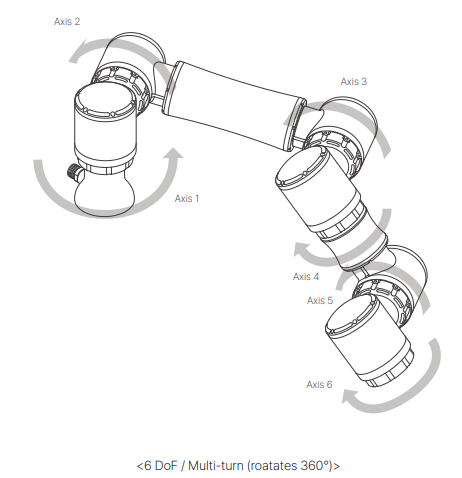
Layout
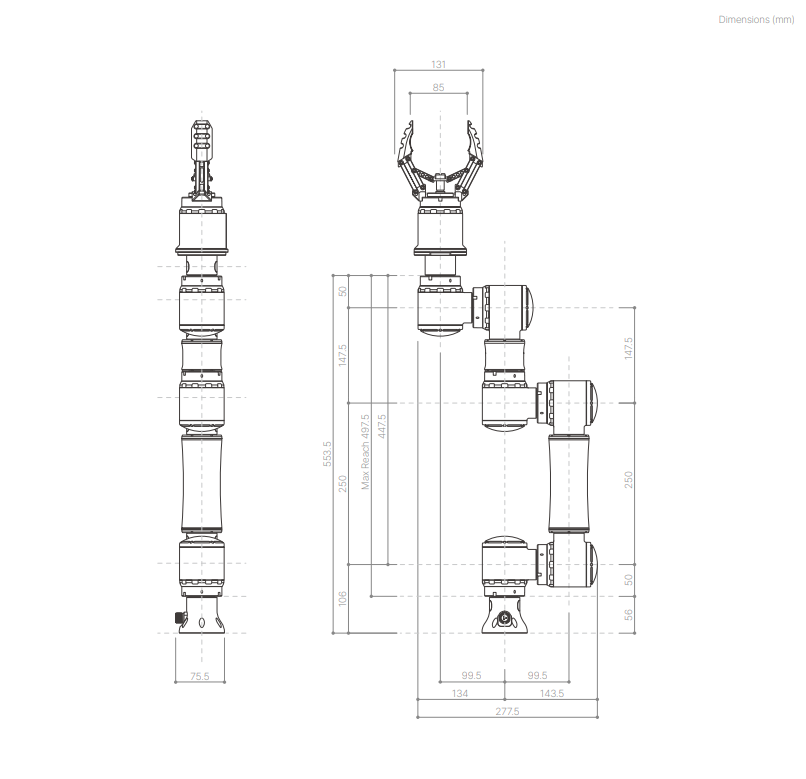
Workspace
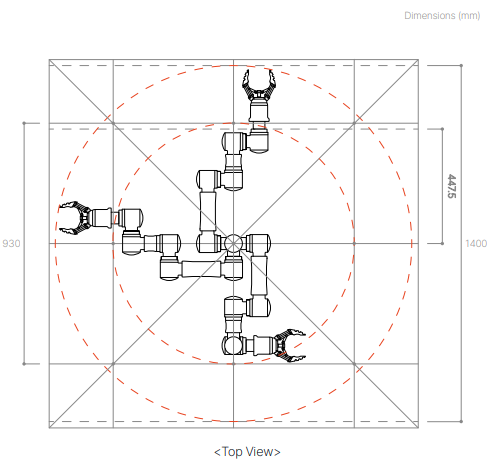
Initial Pose

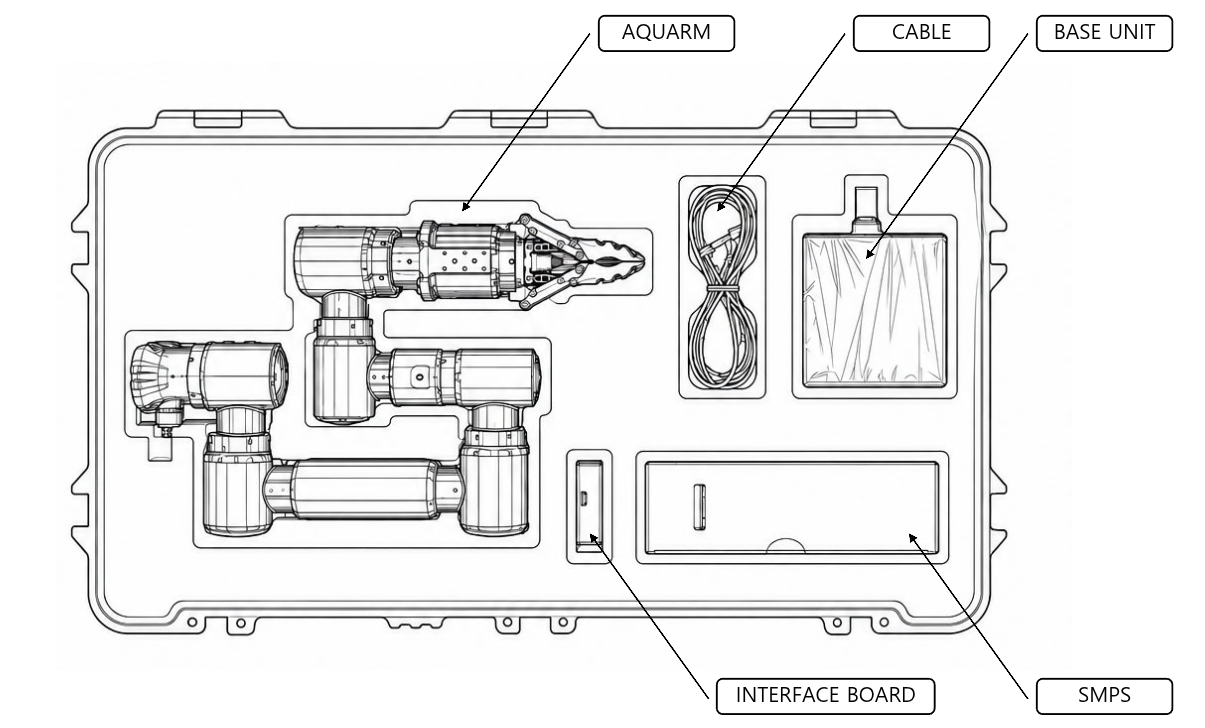
Included Common Items
| Item | Qty | Unit |
|---|---|---|
| Aquarm | 1 | EA |
| Base Unit | 1 | EA |
| Interface Board | 1 | EA |
| Power Supply | 1 | EA |
| Cables | 1 | SET |
Packaging